Buy in Germany
checked 2026-11-06Sellers, prices and stock as their pages showed them. No enquiry is sent from this site.
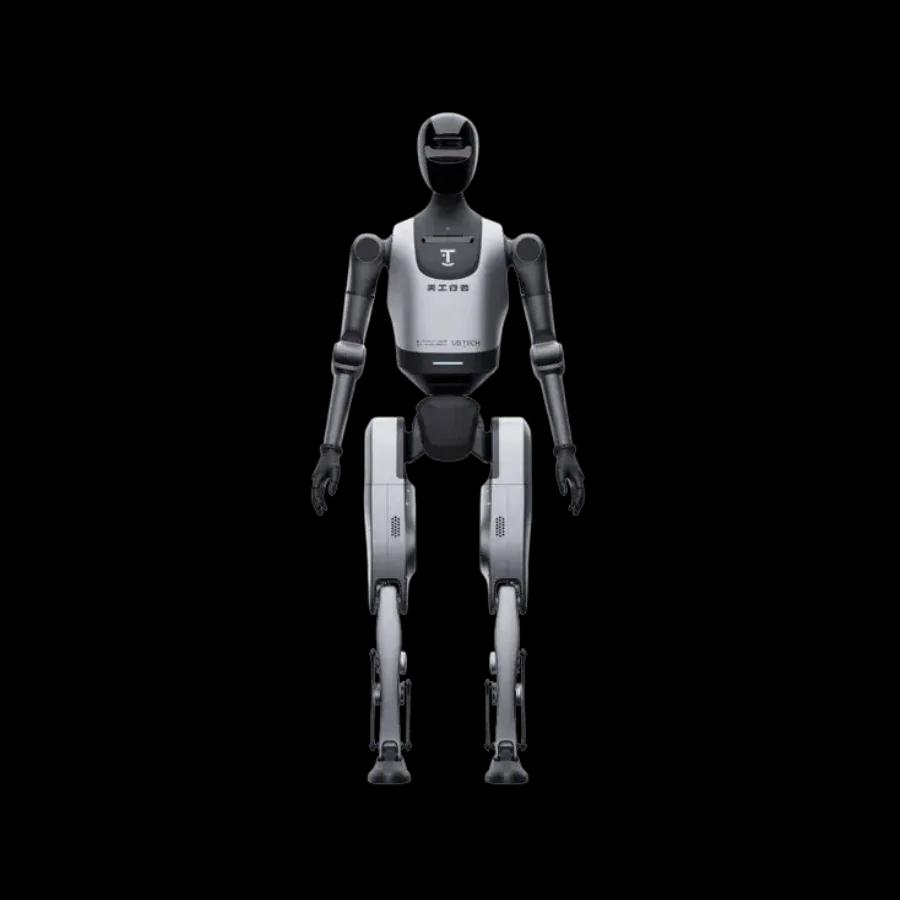
Terra Robotics lists the Walker Tienkung in its Embodied Intelligence version, price on request.
Terra Robotics (Terra Connect GmbH) DE · distributor
Product page ↗Contact ↗mail@terra-robotics.de+49 5732 8411620
Checked 2026-11-06. Maker’s page ↗
Key facts
All specifications- Moves on
Legs
- Height
1.72 m
Maker · ubtrobot.com ↗- Weight
- Arms
2
- Hands
Multi-finger hands
- Payload per arm
3 kg
- Carry on body
- Not published
- Runtime
- Max speed
- Not published
- Stairs
- Not published
- Outdoors
- Not published
- IP rating
- Not published
Jobs
Made for this work 1
- Test learned manipulation policies on a physical humanoidMade for this work
Did similar work 1
- Record humanoid manipulation demonstrationsDid similar work · Research platform for embodied manipulation and teleoperation data collection
Specs fit 8
- Check components before assembly handoffFactory parts-preparation trial
- Develop coordinated arm-and-leg controlSupervised mobile-manipulation research area
- Kit fittings and hardware for element assemblyPrefab timber house factory
- Load sheet-metal parts into welding fixturesAutomotive body shop
- Pick automotive components from flow racksAutomotive parts-sorting station
Show 3 more
- Research picking objects from floor levelControlled laboratory floor and tabletop
- Return empty totes after pickingWarehouse empty-container return
- Study fingertip contact during humanoid graspsDexterous manipulation research cell
Needs add-ons or a trial 19
- Connect sprinklers to the branch lines with flexible hoses in suspended ceilingsSprinklers and extinguishing systems
- Fit lever handles to interior doorsJoinery, interior doors and hardware
- Insert insulation batts into the frame baysPrefab timber house factory
- Install presence detectors in suspended ceilingsBuilding automation
- Install sprinklers and set them to the ceilingSprinklers and extinguishing systems
Show 14 more
- Lay carpet tiles on tackifierFloor coverings and parquet
- Lay click parquet planks floating on an underlayFloor coverings and parquet
- Lay click vinyl planks floatingFloor coverings and parquet
- Lay drainage pipes inside the building to fallsWater, gas and drainage installations
- Lay impact-sound insulation and edge strips under a floating screedScreed
- Mount, connect and address room temperature controllersBuilding automation
- Preset thermostatic radiator valves for hydraulic balancingHeating installations
- Recover beverage cartons from paper linesMaterial recovery facility
- Recover light recyclables from residue beltsMaterial recovery facility
- Set corner beads before plasteringPlaster and stucco
- Tape the airtight window connections in prefabricated facade elementsFacade element prefabrication
- Test returned portable electrical tools before the next hireEquipment rental depot and workshop
- Test screed moisture with the CM method before coveringScreed
- Research reaching switches and control buttonsInstrumented laboratory wall and control-panel mock-up
Where it has worked
- Made for this work
Research platform for embodied manipulation and teleoperation data collection
UBTECH Robotics ↗
Specifications
10 valuesSpecifications by configuration
1 configurationWhat each version's maker or seller states, with the exact source text. A source label says who makes the claim, not that it is proven; unknown means not published.
UBTECH Walker Tienkung Embodied IntelligenceEmbodied Intelligence (with dexterous hands)10 specifications · 4 research gaps · reviewed Per arm 3 kgRuntime 3 hShow all 10 specifications and capabilities
- Height
- Weight
approx.
- Degrees of freedom
- DOF per arm
- DOF per hand
- Single-hand payload
- Runtime
UBTECH: 3 h endurance; Terra: 3.5 h operation, 6 h standby
- Hot-swap battery
- Compute
- Software
- ROS 2, full motor and sensor API, URDF models, RL training frameworksManufacturer sourceUBTECH Robotics ↗ · checked
Capabilities and equipment
- Legs
- YesField-level source not recorded
- Wheels
- NoField-level source not recorded
- Tracks
- NoField-level source not recorded
- Level floors
- YesField-level source not recorded
- Rough ground
maker claim for the Walker Tienkung series (both versions share the same 6-DOF legs); the maker's user manual (PDF p.17) advises against uneven ground
Exact source text
Quote context: maker claim for the Walker Tienkung series (both versions share the same 6-DOF legs); the maker's user manual (PDF p.17) advises against uneven ground
Navigate Any Terrain, Effortlessly
- Stairs
- Unknown
- Outdoor use
- Unknown
- Number of arms
- 2Field-level source not recorded
- Hands or end effectors
- Dexterous handsField-level source not recorded
- Hands included
- YesField-level source not recorded
- Payload per arm
- 3 kgField-level source not recorded
- Payload on body or base
- Not applicable
- IP rating
- Unknown
- SDK / development interface
- ROS 2, open motor/sensor APIField-level source not recorded
Operating conditions and configuration notes
- Research and education platform; UBTECH sells it under AI Education, RobotShop under the name Walker E Pro.
- The 3 kg payload is per hand, from UBTECH's product page.
- Runtime about 3 h continuous, 6 h standby (RobotShop and Terra).
Still missing for UBTECH Walker Tienkung Embodied Intelligence
Payload, both arms · IP rating · Stairs · Outdoor use
Background sources for the capability record
These sources are attached to the record as a whole. Only a source displayed beside a value is linked to that field.
- Walker Tienkung product page ↗Manufacturer source · checked
- UBtech Walker Tienkung ↗Reported · seller · checked
- Ubtech Humanoid Robot Walker E Embodied Intelligence (Walker E Pro, also known as Tienkung) at RobotShop Europe ↗Reported · seller · checked
More detail
Evidence profileShowHide
Robot evidence profile
CheckedEvidence for each configuration
Claims, demonstrations, pilots and deployments describe different levels of evidence. A demonstration does not establish working-site readiness.
UBTECH Walker Tienkung Embodied Intelligence1 published claim · 4 missing capability fields
Configuration: Embodied Intelligence (with dexterous hands)
- Published claim
Research platform for embodied manipulation and teleoperation data collection
Location not recorded · Event date not recorded
UBTECH Robotics ↗ · Manufacturer source · checked
What is still missing
Payload, both arms · IP rating · Stairs · Outdoor use
- How the Walker Tienkung relates to the Tien Kung robots of the Beijing Humanoid Robot Innovation Center is not stated by UBTECH.
Sources
4 pages- Walker Tienkung product page ↗UBTECH Robotics · manufacturer · checked 2026-11-06
- UBtech Walker Tienkung ↗Terra Robotics · seller · checked 2026-11-06
- UBTECH partners with collaborators to accelerate global expansion (Terra Robotics, ROSSMANN) ↗UBTECH Robotics · manufacturer · checked 2026-10-02
- Ubtech Humanoid Robot Walker E Embodied Intelligence (Walker E Pro, also known as Tienkung) at RobotShop Europe ↗RobotShop · seller · checked 2026-10-02