Buy in Germany
checked 2026-10-02Sellers, prices and stock as their pages showed them. No enquiry is sent from this site.
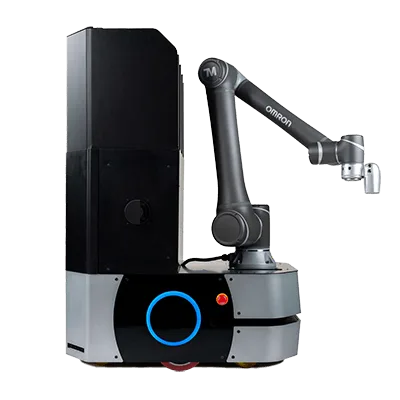
OMRON says it does not sell the integrated mobile manipulator as one product; it provides integration guides and integrator partners for the TM14 + LD250 combination. Ask OMRON Europe (German contact page) for a partner.
OMRON Industrial Automation Europe NL · manufacturer
Checked 2026-10-02. Maker’s page ↗
Key facts
All specifications- Moves on
Wheels
- Height
- Not published
- Weight
- Not published
- Arms
1
- Hands
Hands sold separately
- Payload per arm
- Carry on body
- Runtime
- Not published
- Max speed
- Stairs
- Not published
- Outdoors
- Not published
- IP rating
- Not published
Jobs
Needs add-ons or a trial 17
- Bring fittings, fixings and tools to the installersSite setup and logistics
- Check components before assembly handoffFactory parts-preparation trial
- Develop coordinated arm-and-leg controlSupervised mobile-manipulation research area
- Feed small components to a station in the clean zonePrefab timber house factory
- Kit fittings and hardware for element assemblyPrefab timber house factory
Show 12 more
- Label finished pipe spools and pack them per floor for deliveryBuilding-services prefabrication (TGA)
- Pack standard fitting sets at stable volumesPrefab timber house factory
- Palletise small components at the end of the linePrefab timber house factory
- Pick automotive components from flow racksAutomotive parts-sorting station
- Pick material kits per floor and crewConstruction logistics hub
- Record humanoid manipulation demonstrationsHumanoid learning and teleoperation laboratory
- Research picking objects from floor levelControlled laboratory floor and tabletop
- Restock fastener magazines, clear packaging, tidy workstationsPrefab timber house factory
- Sequence automotive parts into delivery trolleysAutomotive assembly logistics
- Study fingertip contact during humanoid graspsDexterous manipulation research cell
- Test learned manipulation policies on a physical humanoidRobot learning evaluation cell
- Research reaching switches and control buttonsInstrumented laboratory wall and control-panel mock-up
Where it has worked
- Made for this work
Maker names pick and place, machine tending, inspection and moving parts to inspection stations
OMRON Europe ↗
Specifications
5 valuesSpecifications by configuration
1 configurationWhat each version's maker or seller states, with the exact source text. A source label says who makes the claim, not that it is proven; unknown means not published.
OMRON MoMa TM14 + LD250TM14 + LD2505 specifications · 6 research gaps · reviewed Per arm 14 kgBody / base payload 250 kgShow all 5 specifications and capabilities
- Mobile robot payload
LD-250 platform alone
- Arm
- Arm payload
TM14, reach 1,100 mm (arm data sheet values)
- Arm reach
TM14
- Max. speed
LD-250 platform alone
Capabilities and equipment
- Legs
- NoField-level source not recorded
- Wheels
- YesField-level source not recorded
- Tracks
- NoField-level source not recorded
- Level floors
- YesField-level source not recorded
- Rough ground
- Unknown
- Stairs
- Not applicable
- Outdoor use
- Unknown
- Number of arms
- 1Field-level source not recorded
- Hands or end effectors
- OptionalField-level source not recorded
- Hands included
- Unknown
- Runtime
- Unknown
- IP rating
- Unknown
- SDK / development interface
- Unknown
Operating conditions and configuration notes
- Integrated system, so payload, runtime and safety depend on the integrator's build.
Still missing for OMRON MoMa TM14 + LD250
Runtime · IP rating · Rough ground · Outdoor use · Hands included · SDK / development interface
Background sources for the capability record
These sources are attached to the record as a whole. Only a source displayed beside a value is linked to that field.
- Omron Mobile Manipulator Solution ↗Manufacturer source · checked
- LD series mobile robots ↗Manufacturer source · checked
- TM collaborative robots ↗Manufacturer source · checked
More detail
Evidence profileShowHide
Robot evidence profile
CheckedEvidence for each configuration
Claims, demonstrations, pilots and deployments describe different levels of evidence. A demonstration does not establish working-site readiness.
OMRON MoMa TM14 + LD2501 published claim · 5 missing capability fields
Configuration: TM14 + LD250
- Published claim
Maker names pick and place, machine tending, inspection and moving parts to inspection stations
Location not recorded · Event date not recorded
OMRON Europe ↗ · Manufacturer source · checked
What is still missing
Runtime · IP rating · Rough ground · Outdoor use · Hands included
- Which integrators in Germany build OMRON MoMa systems, and at what price.
Sources
3 pages- Omron Mobile Manipulator Solution ↗OMRON Europe · manufacturer · checked 2026-10-02
- LD series mobile robots ↗OMRON Europe · manufacturer · checked 2026-10-02
- TM collaborative robots ↗OMRON Industrial Automation Europe · manufacturer · checked 2026-10-02