Buy in Germany
checked 2026-10-02Sellers, prices and stock as their pages showed them. No enquiry is sent from this site.
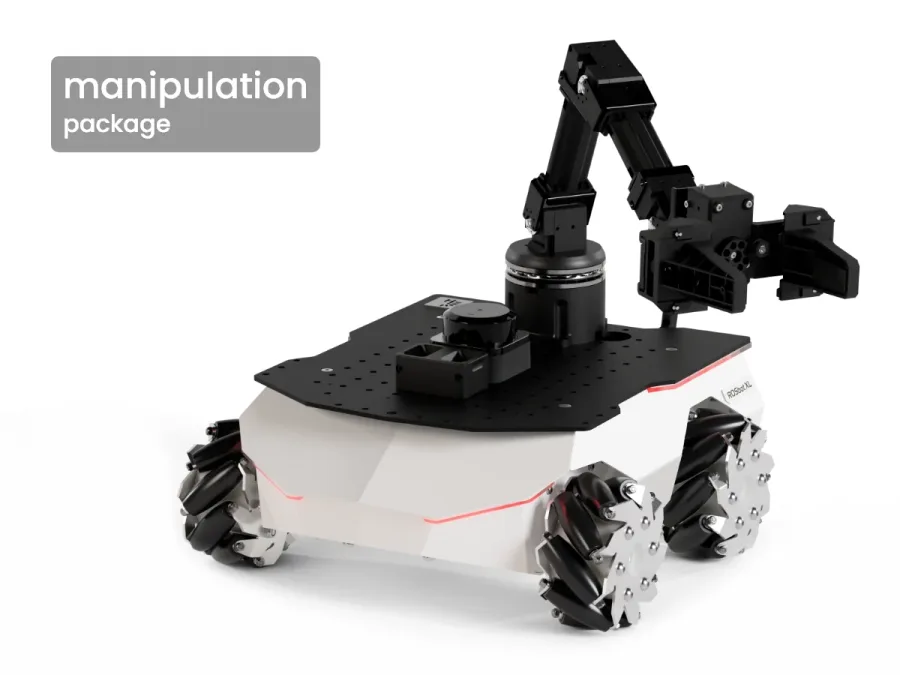
Sold in Husarion's EU online store (Poland, prices in EUR) with Germany among the shipping countries; from €7,519 for the Manipulation Package.
Husarion PL · manufacturer · €7,519
Checked 2026-10-02. Maker’s page ↗
Key facts
All specifications- Moves on
Wheels
- Height
- Not published
- Weight
- Not published
- Arms
1
- Hands
Grippers
- Payload per arm
- Not published
- Carry on body
- Not published
- Runtime
- Not published
- Max speed
- Not published
- Stairs
- Not published
- Outdoors
No
- IP rating
- Not published
Jobs
Needs add-ons or a trial 8
- Check components before assembly handoffFactory parts-preparation trial
- Develop coordinated arm-and-leg controlSupervised mobile-manipulation research area
- Kit fittings and hardware for element assemblyPrefab timber house factory
- Pick automotive components from flow racksAutomotive parts-sorting station
- Research picking objects from floor levelControlled laboratory floor and tabletop
Show 3 more
- Research reaching switches and control buttonsInstrumented laboratory wall and control-panel mock-up
- Restock fastener magazines, clear packaging, tidy workstationsPrefab timber house factory
- Sequence automotive parts into delivery trolleysAutomotive assembly logistics
Where it has worked
- Made for this work
Maker offers it for mobile manipulation with autonomous navigation, with a reference project
Husarion ↗
Specifications
6 valuesSpecifications by configuration
1 configurationWhat each version's maker or seller states, with the exact source text. A source label says who makes the claim, not that it is proven; unknown means not published.
Husarion ROSbot XL Manipulation PackageManipulation Package6 specifications · 5 research gaps · reviewed Show all 6 specifications and capabilities
- Arm
- Battery
Li-Ion 3S 11.1 V 7,800 mAh
- Wheels
- Compute
- ASUS NUC 14 (Core 3, 16 GB RAM); PRO package: NVIDIA Jetson Orin NanoManufacturer sourceHusarion ↗ · checked
- Sensors
- Software
Capabilities and equipment
- Legs
- NoField-level source not recorded
- Wheels
- YesField-level source not recorded
- Tracks
- NoField-level source not recorded
- Level floors
- YesField-level source not recorded
- Rough ground
- Unknown
- Stairs
- Not applicable
- Outdoor use
- NoField-level source not recorded
- Number of arms
- 1Field-level source not recorded
- Hands or end effectors
- GripperField-level source not recorded
- Hands included
- YesField-level source not recorded
- Payload per arm
- Unknown
- Payload on body or base
- Unknown
- Runtime
- Unknown
- IP rating
- Unknown
- SDK / development interface
- ROS 2Field-level source not recorded
Operating conditions and configuration notes
- Indoor research and teaching rover; the arm is a small education manipulator, payload not stated.
Still missing for Husarion ROSbot XL Manipulation Package
Payload per arm · Payload · Runtime · IP rating · Rough ground
Background sources for the capability record
These sources are attached to the record as a whole. Only a source displayed beside a value is linked to that field.
- ROSbot XL store page (configuration packages) ↗Manufacturer source · checked
More detail
Evidence profileShowHide
Robot evidence profile
CheckedEvidence for each configuration
Claims, demonstrations, pilots and deployments describe different levels of evidence. A demonstration does not establish working-site readiness.
Husarion ROSbot XL Manipulation Package1 published claim · 5 missing capability fields
Configuration: Manipulation Package
- Published claim
Maker offers it for mobile manipulation with autonomous navigation, with a reference project
Location not recorded · Event date not recorded
Husarion ↗ · Manufacturer source · checked
What is still missing
Payload per arm · Payload · Runtime · IP rating · Rough ground
- Whether the EUR store price includes VAT for German buyers.
- Arm payload of the OpenMANIPULATOR-X as fitted.
Sources
2 pages- ROSbot XL store page (configuration packages) ↗Husarion · manufacturer · checked 2026-10-02
- Husarion store settings (EUR, ships to DE) ↗Husarion · manufacturer · checked 2026-10-02