Buy in Germany
checked 2026-10-02Sellers, prices and stock as their pages showed them. No enquiry is sent from this site.
EU maker (Netherlands) sells directly via its sales team; no German distributor found; price on request.
CyBe Construction NL · manufacturer
Checked 2026-10-02. Maker’s page ↗
Key facts
All specifications- Moves on
Tracks
- Height
- Not published
- Weight
- Not published
- Arms
1
- Hands
Process tool
- Payload per arm
- Not published
- Carry on body
- Not published
- Runtime
- Not published
- Max speed
- Not published
- Stairs
- Not published
- Outdoors
Yes
- IP rating
- Not published
Jobs
No job on the map fits this robot yet.
Where it has worked
- In daily use
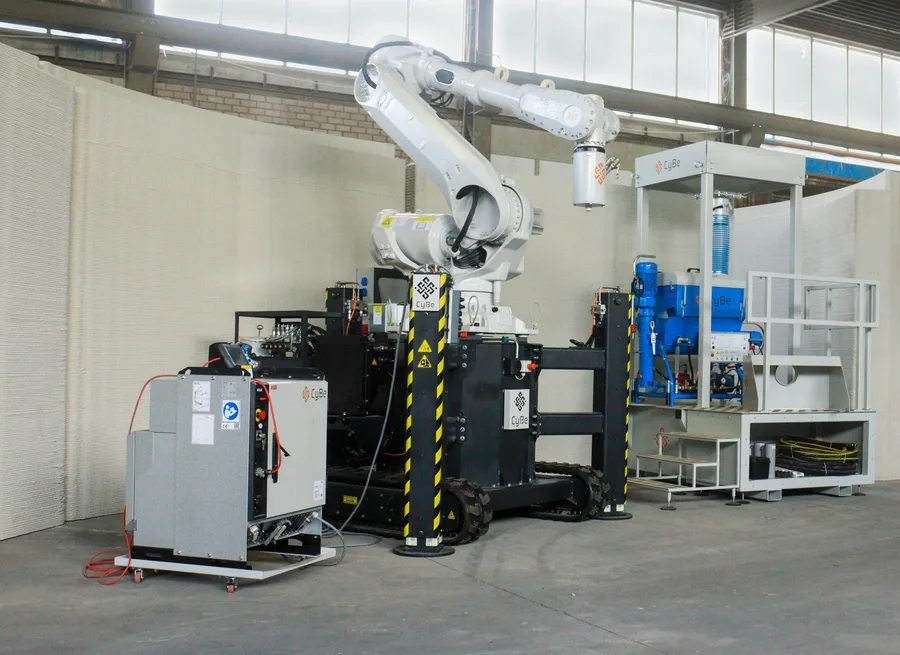
Printed the walls of the Paremoremo House (off-site) · QOROX, Auckland, New Zealand
CyBe Construction ↗
Specifications
2 valuesSpecifications by configuration
1 configurationWhat each version's maker or seller states, with the exact source text. A source label says who makes the claim, not that it is proven; unknown means not published.
CyBe RC (Robot Crawler)Robot Crawler2 specifications · 5 research gaps · reviewed Show all 2 specifications and capabilities
- Circumference x height
standard; extended with hydraulic feet
- Print speed
maker claim for CyBe printers
Capabilities and equipment
- Legs
- NoField-level source not recorded
- Wheels
- NoField-level source not recorded
- Tracks
- YesField-level source not recorded
- Level floors
- YesField-level source not recorded
- Rough ground
- YesField-level source not recorded
- Stairs
- Not applicable
- Outdoor use
- YesField-level source not recorded
- Number of arms
- 1Field-level source not recorded
- Hands or end effectors
- ToolField-level source not recorded
- Hands included
- YesField-level source not recorded
- Payload per arm
- Unknown
- Payload on body or base
- Unknown
- Runtime
- Unknown
- IP rating
- Unknown
- SDK / development interface
- Unknown
Operating conditions and configuration notes
- Hydraulic feet stabilise the machine and extend range; optional rotating nozzle.
- Needs CyBe mortar and a mixing pump.
Still missing for CyBe RC (Robot Crawler)
Payload per arm · Payload · Runtime · IP rating · SDK / development interface
Background sources for the capability record
These sources are attached to the record as a whole. Only a source displayed beside a value is linked to that field.
- CyBe RC (Robot Crawler) ↗Manufacturer source · checked
More detail
Evidence profileShowHide
Robot evidence profile
CheckedEvidence for each configuration
Claims, demonstrations, pilots and deployments describe different levels of evidence. A demonstration does not establish working-site readiness.
CyBe RC (Robot Crawler)1 deployment · 4 missing capability fields
Configuration: Robot Crawler
- Deployment
Printed the walls of the Paremoremo House (off-site)
QOROX, Auckland, New Zealand · Event date not recorded
CyBe Construction ↗ · Manufacturer source · checked
What is still missing
Payload per arm · Payload · Runtime · IP rating
- Price, weight and reach of the arm.
Sources
1 page- CyBe RC (Robot Crawler) ↗CyBe Construction · manufacturer · checked 2026-10-02