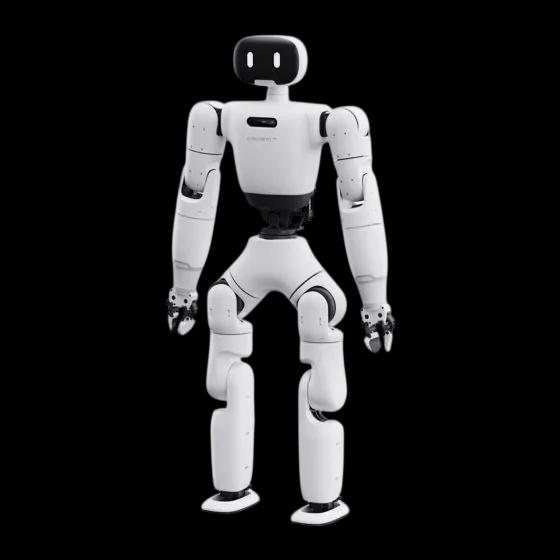
Buy in Germany
checked 2026-11-06Sellers, prices and stock as their pages showed them. No enquiry is sent from this site.
RBTX (igus, Cologne) lists the AGIBOT X1 with price on request. No other German seller was found.
RBTX marketplace (igus SE & Co. KG) DE · reseller
Checked 2026-11-06. Maker’s page ↗
Key facts
All specifications- Moves on
Legs
- Height
- Weight
- Arms
2
- Hands
Hands sold separately
- Payload per arm
- Carry on body
- Not published
- Runtime
- Max speed
- Stairs
- Not published
- Outdoors
- Not published
- IP rating
- Not published
Jobs
Needs add-ons or a trial 1
- Research reaching switches and control buttonsInstrumented laboratory wall and control-panel mock-up
Where it has worked
- Made for this work
Offered as an open-source platform for research, education and industrial applications
igus SE & Co. KG (RBTX) ↗
Specifications
7 valuesSpecifications by configuration
1 configurationWhat each version's maker or seller states, with the exact source text. A source label says who makes the claim, not that it is proven; unknown means not published.
AGIBOT X17 specifications · 6 research gaps · reviewed Per arm 0.5 kgRuntime 2 hShow all 7 specifications and capabilities
- Height
RBTX listing
- Weight
RBTX listing
- DOF
RBTX listing
- Payload per arm
per arm, RBTX listing
- Walking speed
up to, RBTX listing
- Operating time
RBTX listing
- Software
- Open-source software on the AimRT middleware, with ROS 2 simulationManufacturer sourceAGIBOT ↗ · checked
Capabilities and equipment
- Legs
- YesField-level source not recorded
- Wheels
- NoField-level source not recorded
- Tracks
- NoField-level source not recorded
- Level floors
- YesField-level source not recorded
- Rough ground
- Unknown
- Stairs
- Unknown
- Outdoor use
- Unknown
- Number of arms
- 2Field-level source not recorded
- Hands or end effectors
- OptionalField-level source not recorded
- Hands included
- Unknown
- Payload on body or base
- Not applicable
- IP rating
- Unknown
- SDK / development interface
- Open source, AimRT middleware, ROS 2 simulationField-level source not recorded
Operating conditions and configuration notes
- Specs come from the RBTX listing; the AGIBOT product page could not be read.
- RBTX does not state which end effector is supplied.
- At 0.5 kg per arm it is a research platform, not a handling robot.
Still missing for AGIBOT X1
Payload, both arms · IP rating · Stairs · Rough ground · Outdoor use · Hands included
Background sources for the capability record
These sources are attached to the record as a whole. Only a source displayed beside a value is linked to that field.
- AGIBOT X1 on RBTX ↗Reported · seller · checked
- AgiBot X1 software repository ↗Manufacturer source · checked
More detail
Evidence profileShowHide
Robot evidence profile
CheckedEvidence for each configuration
Claims, demonstrations, pilots and deployments describe different levels of evidence. A demonstration does not establish working-site readiness.
AGIBOT X11 published claim · 6 missing capability fields
- Published claim
Offered as an open-source platform for research, education and industrial applications
Location not recorded · Event date not recorded
igus SE & Co. KG (RBTX) ↗ · Reported · seller · checked
What is still missing
Payload, both arms · IP rating · Stairs · Rough ground · Outdoor use · Hands included
- agibot.com could not be read (robots.txt error), so no value is confirmed on the maker product page.
- Which end effector ships with the robot?
- Real delivery time from RBTX.
Sources
2 pages- AGIBOT X1 on RBTX ↗igus SE & Co. KG (RBTX) · seller · checked 2026-11-06
- AgiBot X1 software repository ↗AGIBOT · manufacturer · checked 2026-11-06